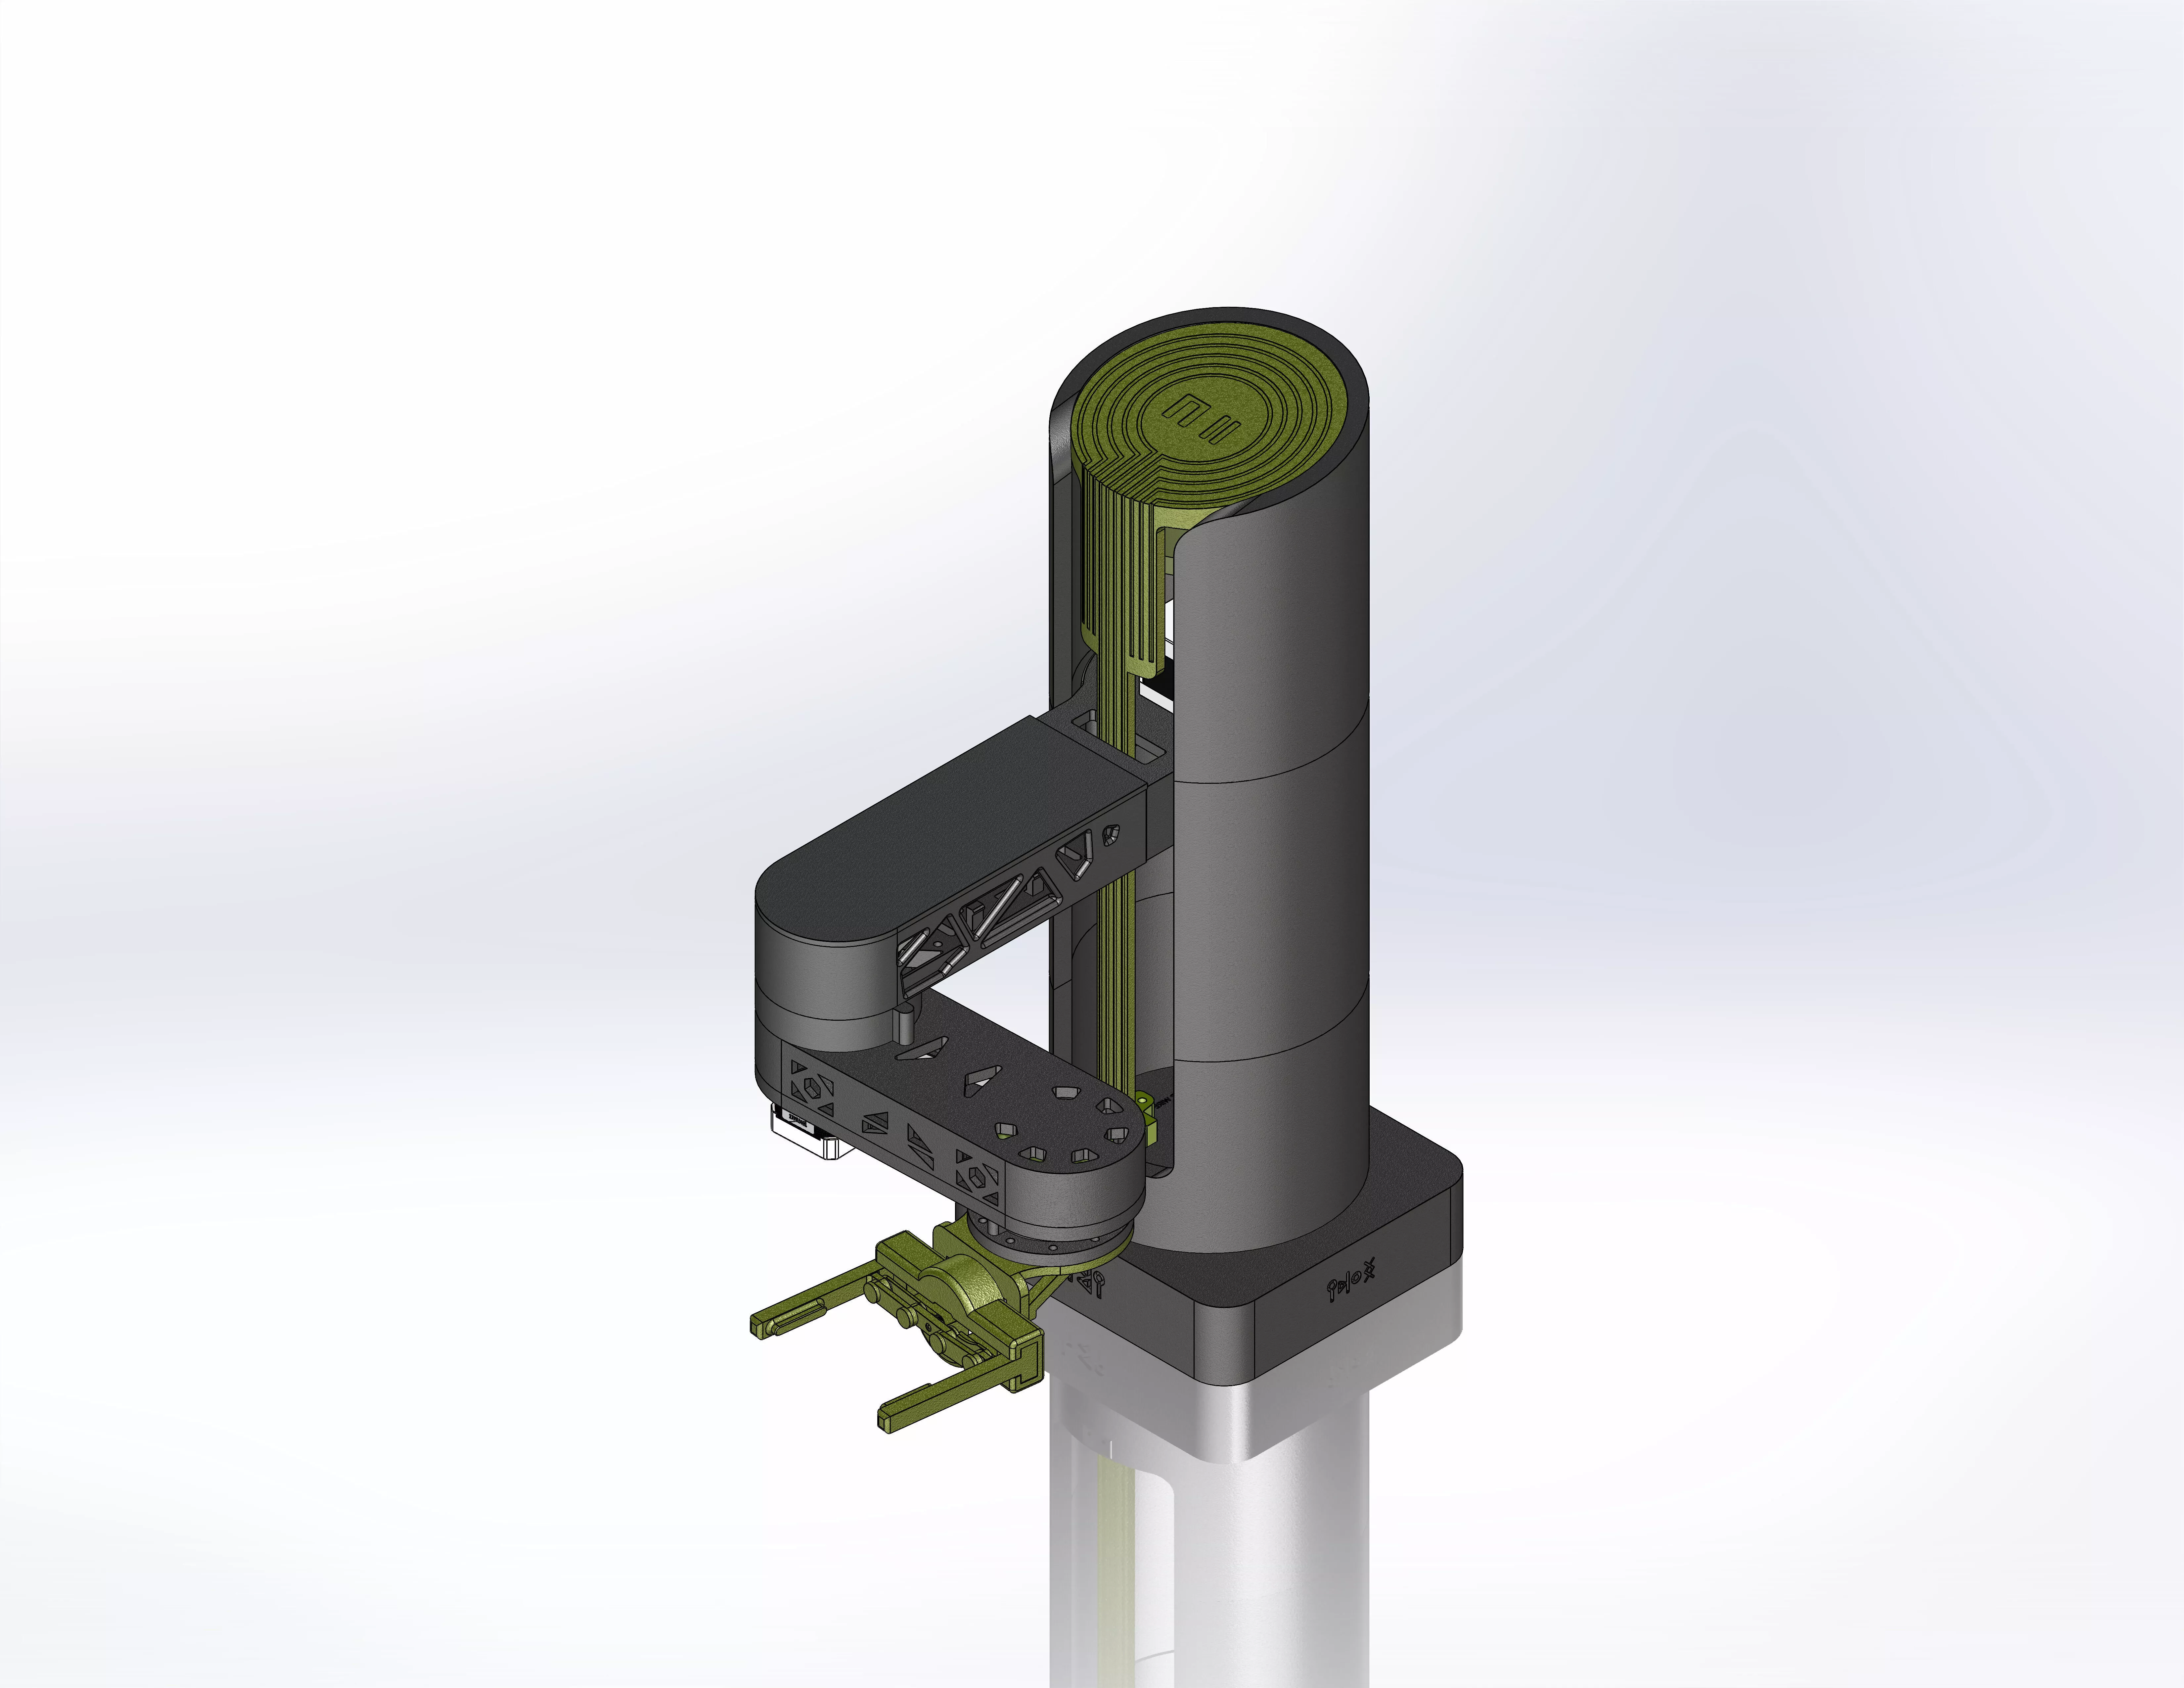
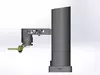
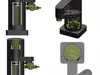
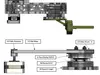
This is a custom-designed** 3-DOF SCARA robotic **arm with a servo gripper, developed as part of a mechatronics graduation project.
The robot is designed as a compact and low-cost platform for learning and experimenting with robotic motion, pick-and-place operations, forward/inverse kinematics, and embedded control.
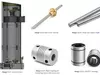
The system uses three NEMA 17 stepper motors for the main axes and an MG90S servo motor for the gripper. The mechanical structure was designed for 3D printing and easy assembly, with approximately 400 mm horizontal reach and a vertical Z-axis.
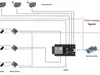
Main Features3-DOF SCARA architectureApproximately 400 mm reachVertical Z-axis motionServo-operated gripperNEMA 17 stepper motor compatibilityDesigned for DRV8825 stepper driversESP32-based control systemForward and inverse kinematics supportHoming and limit-switch integrationModular 3D-printable constructionDesigned for lightweight pick-and-place applicationsThe design is intended for students, robotics enthusiasts, and makers who want to build and experiment with a practical SCARA robotic arm without requiring expensive components.
ALL THE STEP AND STL FILES IN THE SCARA ARM.zip