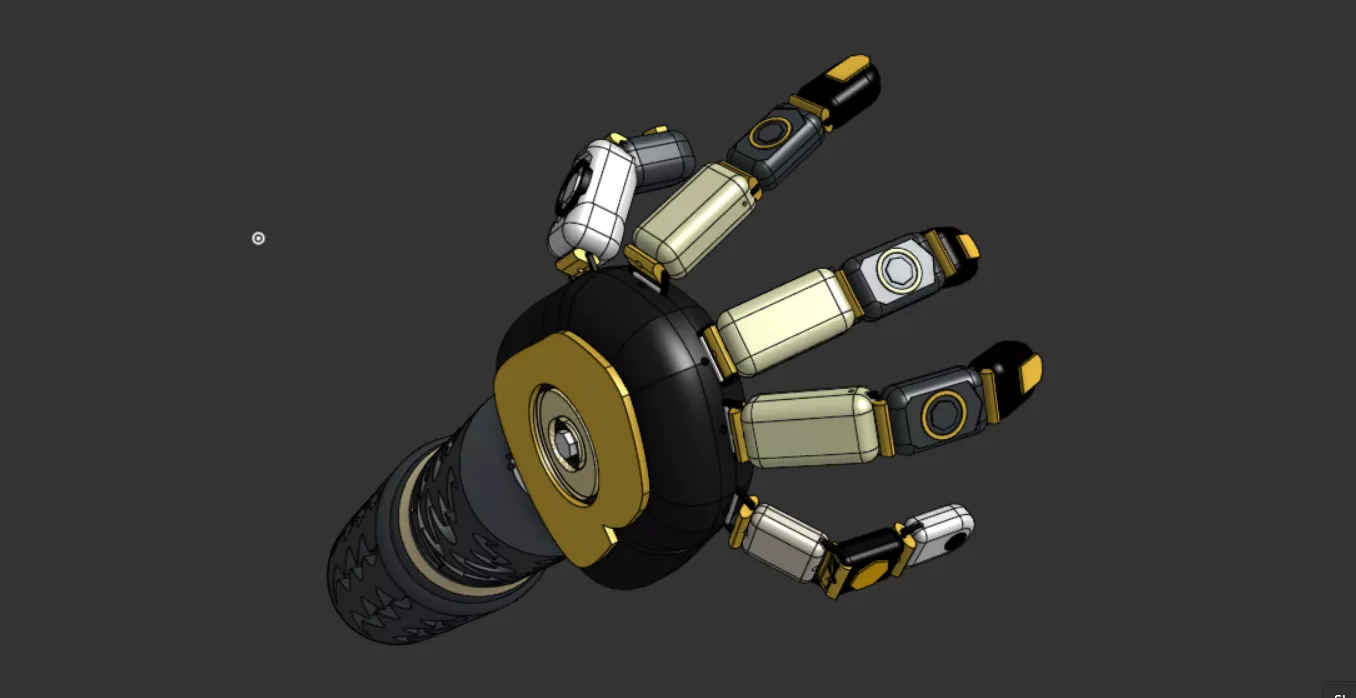
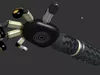
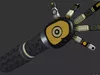
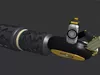
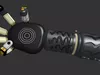
Fully articulated, high-precision robotic prosthetic hand and arm assembly CAD model designed for engineering projects, customization, and 3D printing.
Key Features:
- Multi-Part Articulation: Features fully movable finger joints, wrist rotation mount, and structured forearm housing.
- Tendon Routing Channels: Integrated internal guide paths designed for string/wire actuation (sized for 1 mm to 1.5 mm braided line).
- Dual File Package: Includes both master CAD geometry and print-ready mesh files.
Included File Formats:
- STEP (.step): Universal B-Rep parametric solid CAD file compatible with Fusion 360, SolidWorks, FreeCAD, Onshape, Rhino, and Inventor.
- STL (.stl): High-resolution tessellated mesh optimized for 3D printing slicers (PrusaSlicer, Bambu Studio, Cura).
Manufacturing and Print Settings:
- Recommended Filament: PETG, ABS, or Tough PLA for structural joint durability and wear resistance.
- Layer Height: 0.16 mm to 0.20 mm for precise mechanical tolerances.
- Infill: 20% to 30% Gyroid or Grid infill.
- Supports: Required only for overhangs on finger joint pivots and wrist mounting points.
Required Hardware and Assembly Notes:
- Joint Pinning: Pivot holes are sized at 0.07 in (~1.8 mm). These accept 1.8 mm dowel pins, M1.8 or M2 screws, or standard 1.75 mm 3D printing filament cut to length as pivot pins.
- Adhesive / Bonding: Apply a small amount of CA glue or epoxy to non-moving joint housings and outer palm shell covers to secure components in place and prevent falling out during use.