DESCRIPTION

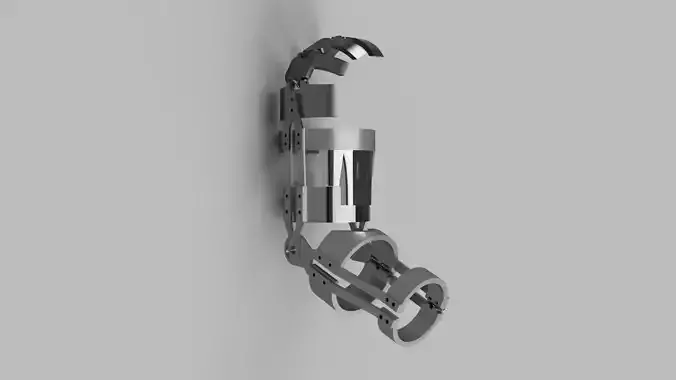
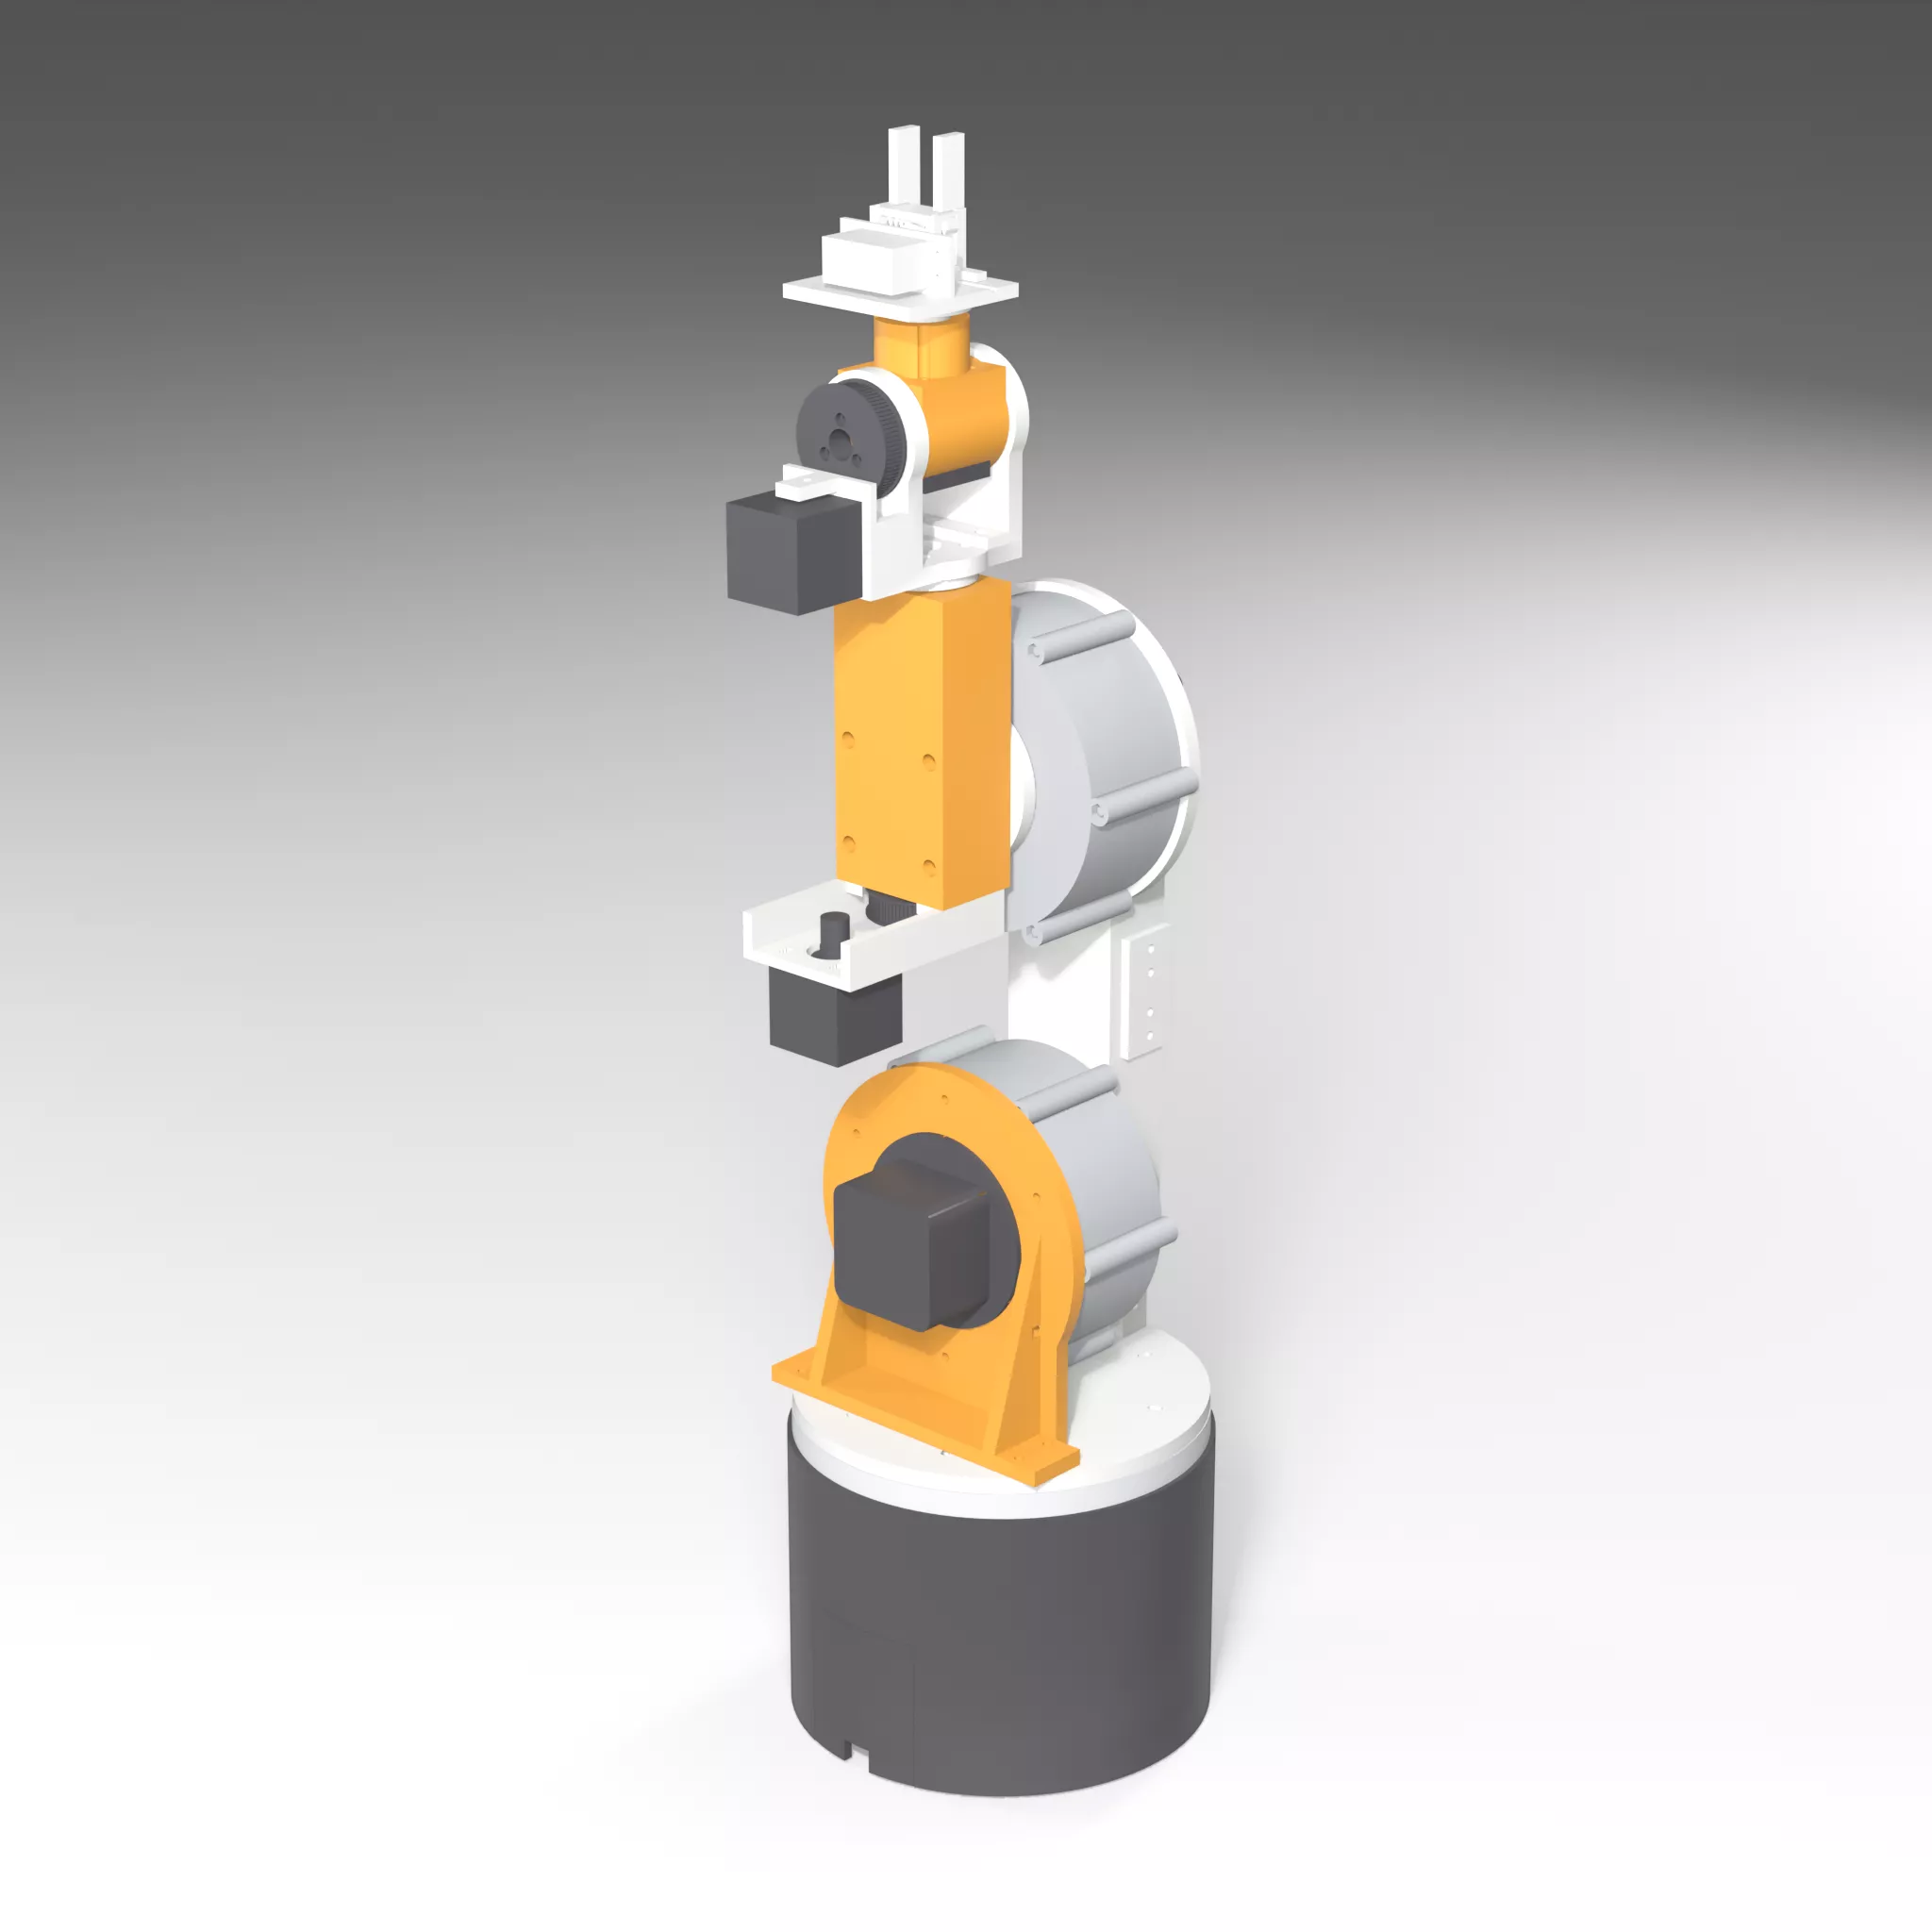
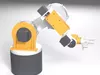
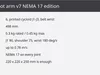
Reach 498 mm, payload 0.3 kg rated (0.45 kg calculated max)Speed: joints up to 360 deg/s (shoulder 75 deg/s), gripper point up to 0.78 m/sPrinted cycloid gearboxes on J1-J3 (NEMA 17), belt wrist, geared J6, spring-balanced shoulder220 x 220 x 250 mm printer; STL already oriented, STEP, BOM, assembly + wiring guides, actuator test rigReady-laid print plates (.3mf, one per 220 x 220 bed) + motion-demo video of the arm (CAD simulation) Designed and verified in CAD and simulation; gearbox capacity is calculated (not yet measured). Images are renders. Digital files only.

REVIEWS & COMMENTS

See what other buyers think about this model - real feedback on quality,
accuracy, and usability.
There are no reviews or comments yet. Please be the first one to write it.
NEW
Recently added to CGTrader - explore one of the latest models on the marketplace.

6 Axis Robot Arm v7 NEMA 17 Printed Cycloidal Gearboxes 3D print model

$6.00
Royalty Free License (no AI)
Like this model to show appreciation to the designer.
See how many times this model was viewed.
Share this model to support the designer and boost their visibility.
File formats
STL
Stereolithography<br />File Size: 69.5 MB
3MF
3D Manufacturing File<br />File Size: 69.5 MB
PNG
PNG<br />File Size: 69.5 MB
MP4
MP4<br />File Size: 69.5 MB
Provided by designer
Information and details shared directly by the model's designer.
3D printing
Indicates whether the designer marked this model as suitable for 3D printing.
Model is prepared for 3D printing
The designer indicates this model is prepared for physical 3D printing and includes printable file formats.
Units
Publish date
Model ID
Chat