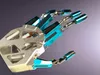
7-DOF Robotic Finger Mechanism – Four-Bar LinkageDescription
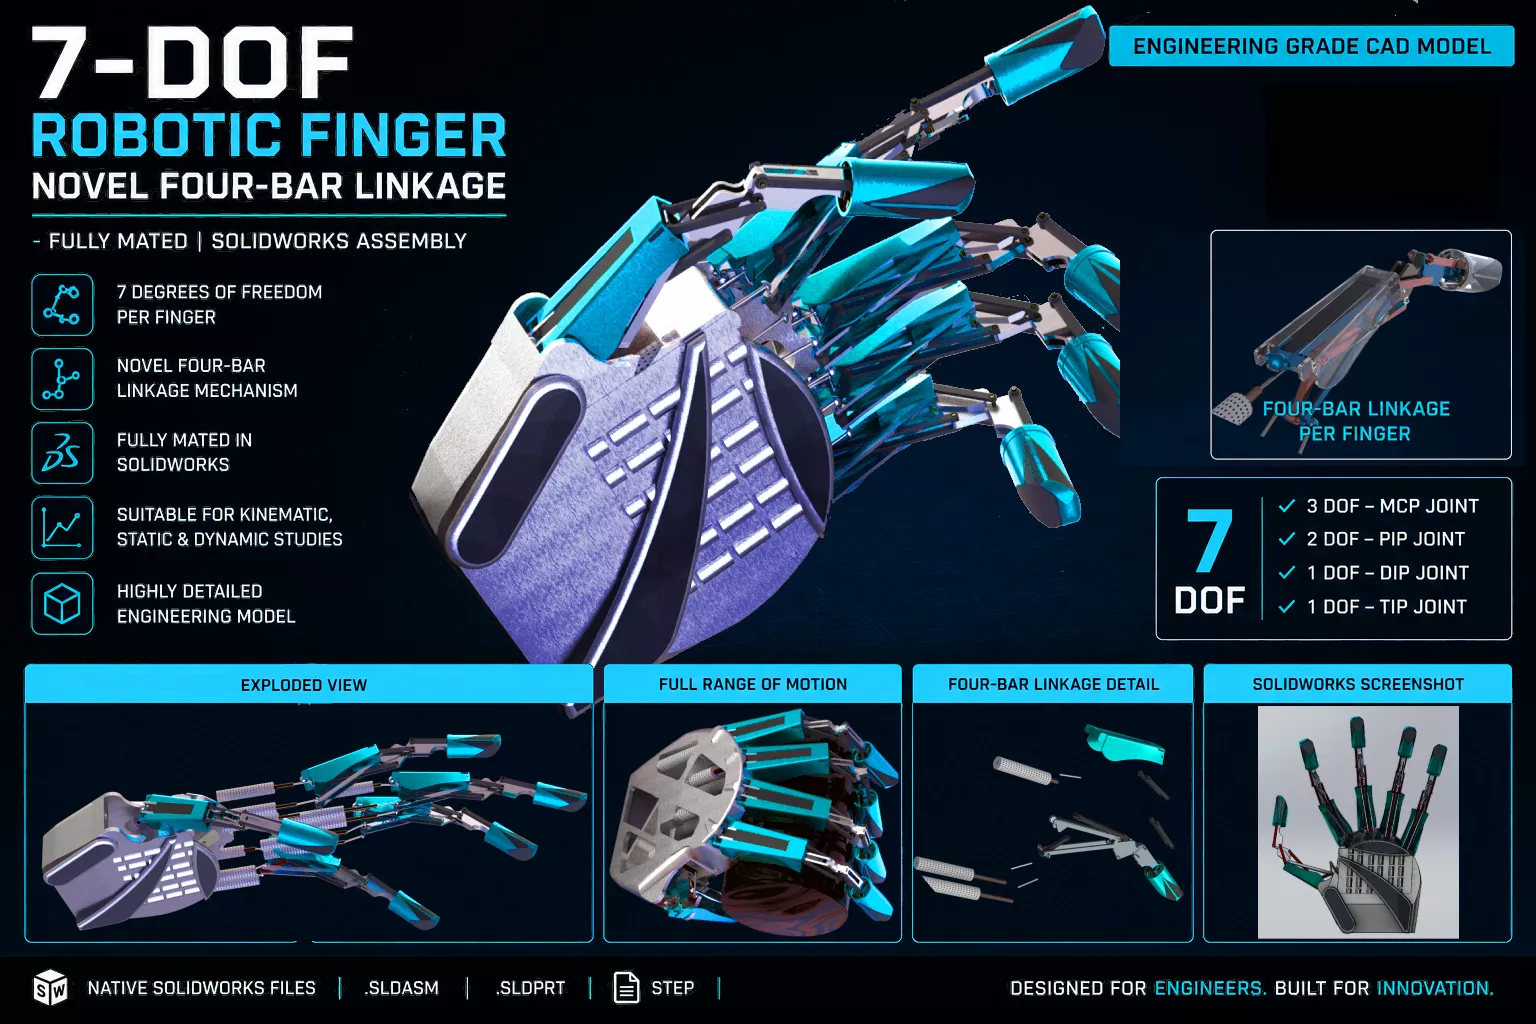
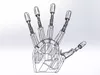
A fully articulated 7-DOF robotic finger mechanism designed around a novel four-bar linkage architecture. This model was developed in SolidWorks as a fully mated mechanical assembly, with functional joint motion and a complete range of kinematic movement.
Unlike many robotic hand models intended primarily for visualization or rendering, this model is designed with mechanical engineering and simulation applications in mind. The individual components are assembled using appropriate SolidWorks mates, allowing the mechanism to be studied and manipulated as a functional mechanical system.
Key Features
- 7 degrees of freedom per finger
- Novel four-bar linkage-based finger mechanism
- Fully assembled and mated in SolidWorks
- Functional joint articulation with a full kinematic range
- Individual mechanical components are modeled separately
- Suitable for studying finger kinematics and mechanism motion
- Suitable for kinematic and static simulations
- Useful for robotics, mechanical engineering, CAD, and research applications
- Designed to be further modified and customized in SolidWorks
- Detailed mechanical geometry suitable for engineering development and prototyping
Engineering Applications
This model can be used as a starting point for:
- Robotic hand development
- Robotic finger mechanism research
- Kinematic analysis
- Static and quasi-static analysis
- Mechanism and linkage studies
- Motion simulation
- CAD and mechanical design projects
- Robotics research and education
- Prosthetic and assistive-device concept development
- Mechanical engineering coursework and demonstrations
- Rapid prototyping and further design development
Mechanical Design
The finger uses a four-bar linkage architecture to generate coordinated motion between the finger segments. The mechanism has been designed to provide controlled articulation while maintaining a compact mechanical structure.
The complete assembly is constrained using SolidWorks mates, allowing the mechanism to move through its intended range rather than functioning only as a static visualization model.
This makes the model particularly useful for users who want to investigate the relationship between linkage geometry, joint motion, and overall finger kinematics without having to build the entire mechanism from scratch.
SolidWorks Assembly
The model is provided as a mechanical CAD assembly with its constituent components. Because the assembly is fully mated, users can directly investigate the mechanism's motion within SolidWorks and use it as a foundation for additional engineering analysis.
The geometry can also be modified to investigate alternative:
- Link dimensions
- Joint configurations
- Mechanical constraints
- Finger geometries
- Actuation concepts
- Motion profiles
Please note: The model represents a mechanical design and simulation-ready CAD assembly. Its suitability for a specific physical application, load case, manufacturing process, or robotic control system should be independently evaluated by the user.
Files Included
The purchased package includes the available native CAD assembly and component files in a verity of formats.
Keywords: robotic hand, robotic finger, 7 DOF, seven degree of freedom, four-bar linkage, four bar mechanism, robotic mechanism, robotic hand mechanism, SolidWorks, CAD assembly, mechanical assembly, kinematics, dynamic simulation, static simulation, robotics, mechanical engineering, linkage mechanism, articulated finger, robot finger, engineering model, research model, simulation model